Talyra Technologies shield logo TALYRA TECHNOLOGIES

Autonomous swarms.
Resilient communications.
Distributed intelligence. Coordinated action.

Enabling the future of defense and critical operations

Decentralized
by design
Built for contested
environments
Resilient mesh
communications
Autonomy on
the edge
Modular
software layer
The problem

Cut the link, and today's swarms fall apart.

Unmanned systems still depend on centralized command links, cloud compute, or a single master node. In contested theaters — active jamming, GPS denial, high packet loss — that dependency is a single point of failure and a single point of detection. Sever it, and a swarm degrades into disconnected, blind individual aircraft.

Today's counter-UAS doctrine is one interceptor against one threat. Saturation attacks are designed to win that math.
Talyra OS

Distributed intelligence. Coordinated action.

Talyra OS is our software-only coordination layer for teams of unmanned systems. The same software runs on every platform in the team, so the team can share what it knows and coordinate what it does without a master node or a cloud dependency. One distributed computer, not a fleet of individual vehicles.

Less to micromanage

The operator gives the team a mission. The platforms work out how to share the work between them. The goal is to keep operator workload from growing with every added platform.

Keeps working as the team changes

Designed to continue when links degrade or when platforms drop out, instead of depending on one controller that can be cut off.

Software on the platforms you have

Talyra OS is a software layer, not an airframe. It is built to be integrated with the platforms, sensors and command systems an operator already fields.

From one aircraft to a coordinated team

Conceptual visualization Keep scrolling

One aircraft. One operator.

A single aircraft does what its operator tells it. Nothing more to coordinate.

Add more aircraft.

With more aircraft, manual control stops scaling. More vehicles should not mean more operators.

One team.

With Talyra OS the operator sets the mission and the aircraft coordinate between themselves. Distributed intelligence. Coordinated action.

From one aircraft to a team
Conceptual visualization

One aircraft. One operator.

A single aircraft does what its operator tells it. Nothing more to coordinate.

Add more aircraft.

With more aircraft, manual control stops scaling. More vehicles should not mean more operators.

One team.

With Talyra OS the operator sets the mission and the aircraft coordinate between themselves.

Platforms

Air. Ground. Maritime.

Talyra OS is designed to be platform-agnostic. Today the demonstrated work is in the air domain. Ground and maritime are planned applications, and we are looking for integration partners to work on them.

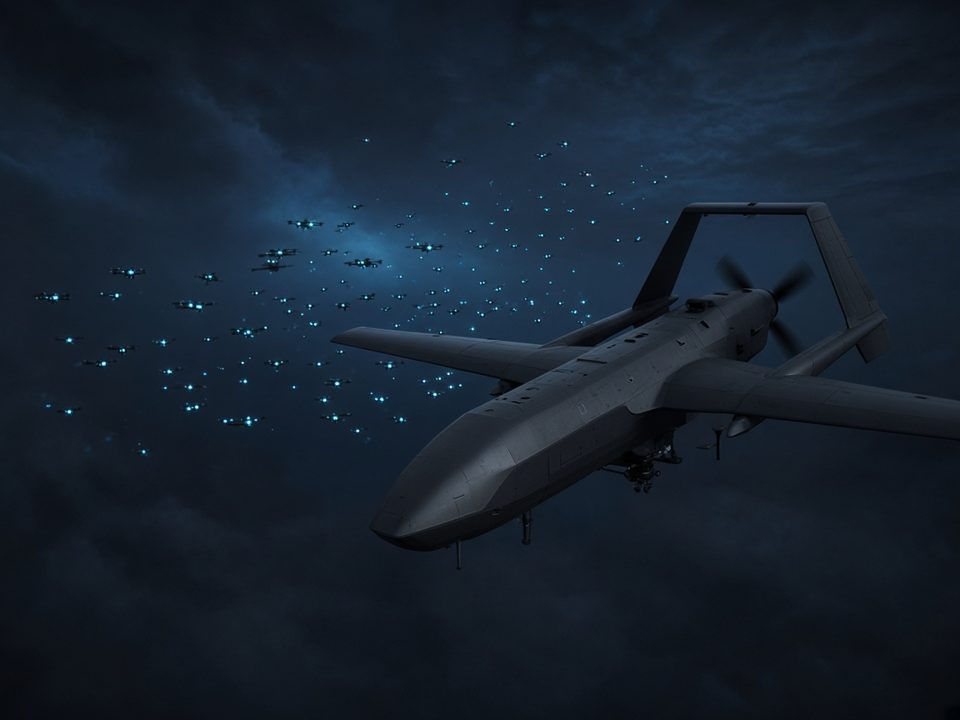
Illustration: a twin-boom fixed-wing unmanned aircraft at night with a swarm of small drones behind it
Demonstrated in simulation

Air

Categories: multirotor and fixed-wing platforms.

Demonstrated so far: multirotor only, with stock PX4 autopilot software in software-in-the-loop simulation. ArduPilot integration is in development. No flight hardware results yet.

See the validation
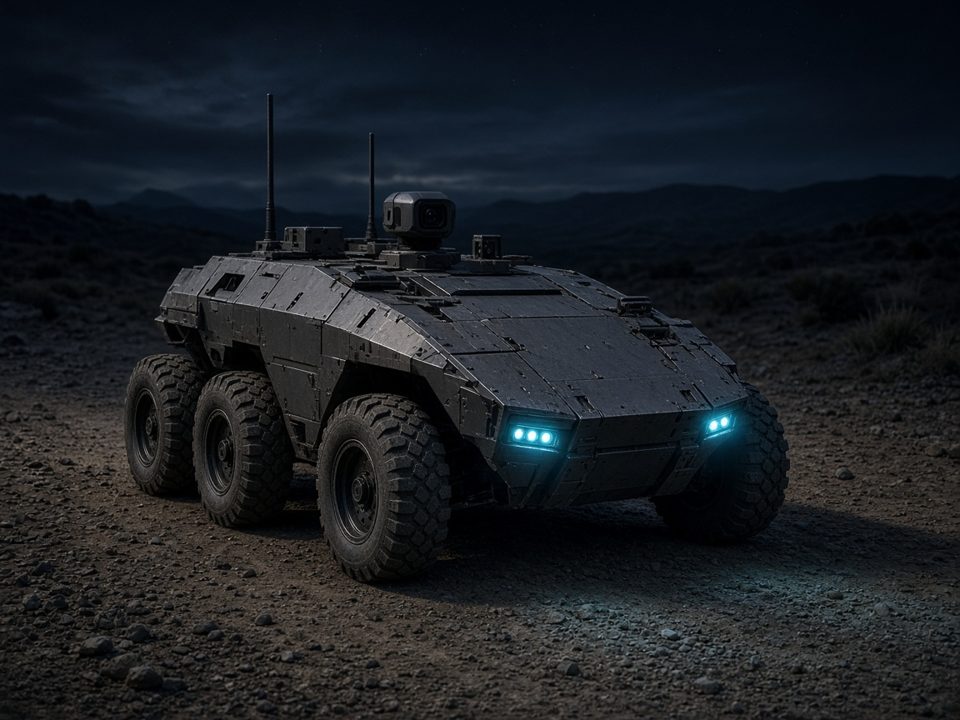
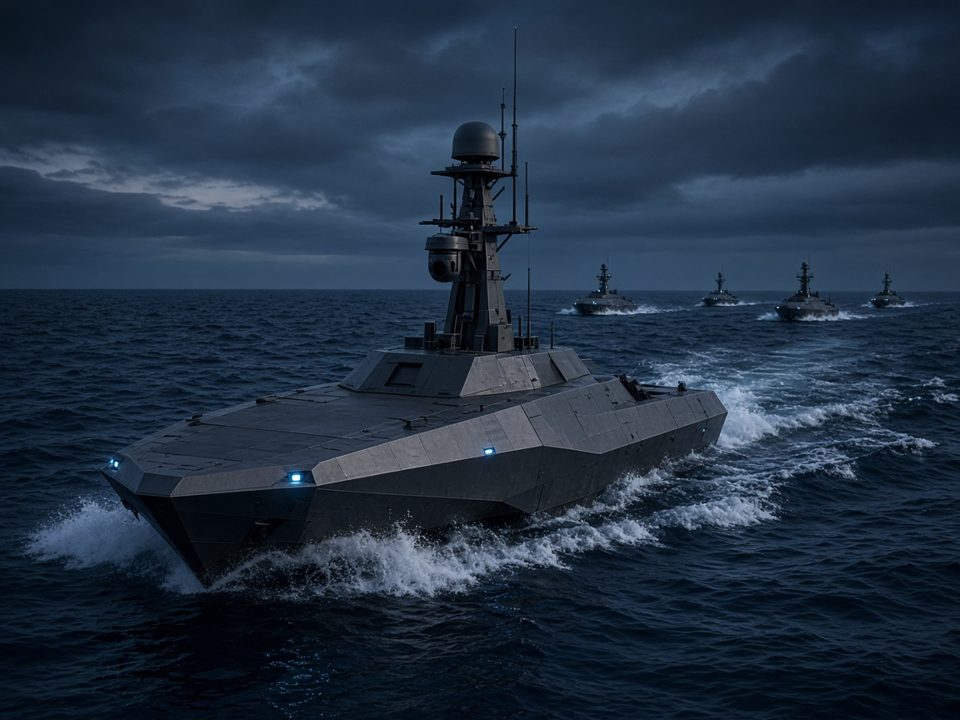
Illustration: a rugged six-wheeled unmanned ground vehicle with antennas and a camera turret on gravel at night
Planned application

Ground

Teams of unmanned ground vehicles coordinating the same way as air teams.

Not yet demonstrated. Seeking integration partners.

Seeking integration partners
Illustration: an unmanned surface vessel with a sensor mast at sea at night, with a squad of similar vessels behind it
Planned application

Maritime

Teams of unmanned surface vessels coordinating the same way as air teams.

Not yet demonstrated. Seeking integration partners.

Seeking integration partners
Solutions

One coordination layer. Two missions.

Talyra is a dual-use autonomy platform for defense and civil security: the same decentralized software serves defense customers and civil operators who need to protect a site from uncooperative drones.

Solutions · Defense

Defense

Area defense against saturation sUAS attacks for expeditionary and fixed sites — coordination designed to keep working under jamming, GPS denial, and attrition. Interceptors act as one team instead of one-on-one.

  • Expeditionary sites
  • Fixed sites
  • Counter-swarm
See the capabilities
Solutions · Civil & Homeland Security

Civil & Homeland Security

Protection of critical infrastructure — data centers, stadiums, utilities, airports — from uncooperative drones, and multi-robot coordination middleware for applications beyond the security domain.

  • Critical infrastructure
  • Public venues
  • Multi-robot coordination
Integrate with us
Capabilities

What Talyra OS is built to do.

01

Decentralized coordination

Coordination without a central controller. Platforms share the work locally and adapt as mission conditions change.

Demonstrated in simulation

02

Degraded-comms operation

Designed to keep coordinating under intermittent and degraded communications, with reduced reliance on continuous connectivity.

Demonstrated in simulation

03

Adapting as availability changes

When platforms become unavailable, the remaining team adapts its work and coverage to support the mission.

Demonstrated in simulation

04

Edge autonomy

The software is designed to run locally on edge compute on each platform: no cloud and no base station. GPS-denied and EW-contested operation is the design point.

Design basis

Integration

Built for System-of-Systems Integration

Talyra OS is being developed as an interoperable coordination layer connecting unmanned platforms, sensors, and command-and-control systems. Our goal is to support integration through documented interfaces, giving partners flexibility across platforms and vendors.

C2 Integration

Designed to connect mission-level command with autonomous team coordination.

Platform Interoperability

An integration approach spanning compatible vehicles, sensors, and communications systems.

Partner Interfaces

Working toward documented interfaces for platform manufacturers and system integrators.

Working toward open, documented integration interfaces.

  • C2 Providers
  • Platform Manufacturers
  • Sensor Developers
  • System Integrators
Conceptual integration overview
Sensors & C2
Talyra OSCoordination software
Unmanned Platforms
Connect mission intent with coordinated autonomous action. Conceptual only: no central server is required. Interfaces beyond those marked implemented below are planned or in development.
Interface status today

Sensors & radios

We are building a vendor-neutral track input for ground radar, so that radar tracks can be consumed by the team.

  • SAPIENT detection-stream ingest: implemented and exercised offline in simulation
  • Peer-to-peer networking over compatible IP radios: design intent

Command & control

Standards-based message formats for existing C2 and fusion systems.

  • Cursor-on-Target (CoT): message encoder implemented; not yet tested with a TAK client
  • SAPIENT: ingest scope above

Platforms & autopilots

Platform-agnostic by design. Today the software runs against stock PX4 in software-in-the-loop simulation.

  • PX4 (software-in-the-loop)
  • ArduPilot (integration in development)
Scope. These are interface capabilities, not completed end-to-end integrations. No fielded sensor, radio, C2 or platform integration is claimed.

Explore Talyra OS on your platform.

Discuss your vehicles, interfaces, and mission requirements with our engineering team.

  1. Define the Mission
  2. Evaluate in Simulation
  3. Plan Hardware Integration

This is how we engage with new partners. It is not a statement that any platform is already compatible.

Validation

Simulation-first, with the limits stated.

We validate in simulation before any hardware risk is taken, including stock PX4 autopilot software in software-in-the-loop simulation. Hardware-in-the-loop integration on flight-controller hardware is under way.

SIMULATION. Illustrative Talyra simulation demonstrating multi-agent coordination under constrained communications. Not flight footage; no hardware performance is represented. Sensor graphics are illustrative and do not represent validated sensor performance.
Results to date · simulation
250

PX4 autopilot instances (multirotor, PX4 SIH simulation) ran concurrently in software-in-the-loop simulation on a single host. Vehicles hovered; this is simulation-scale integration, not flight.

0

Assignment conflicts observed in randomized static task-assignment tests in simulation.

Low-bandwidth

Coordination designed for constrained communications and evaluated in simulation.

Talyra coordination software ran alongside the PX4 instances in the same simulation.

These results demonstrate simulation-scale integration, not flight performance. Hardware-in-the-loop integration is underway; hardware validation results are not yet available.

  • Simulation demonstratedCoordination results above come from simulation, including PX4 software-in-the-loop.
  • Integration statusPX4 running in software-in-the-loop; ArduPilot integration in development; hardware-in-the-loop integration underway.
  • ReadinessTRL 3 (self-assessed), working toward TRL 4.
  • Technical briefings availableMethodology, integration requirements and results are shared in briefings, not published here.

Request a technical briefing on our validation methodology, integration requirements, and results.

Company

Software for contested skies.

Talyra Technologies develops a dual-use autonomy platform for defense and civil security: decentralized coordination software for teams of unmanned systems, following a simulation-first methodology.

Defense

Area defense against saturation sUAS attacks for expeditionary and fixed sites.

Civil & Homeland Security

Protection of critical infrastructure — data centers, stadiums, utilities, airports — from uncooperative drones; multi-robot coordination middleware beyond the security domain.

Team

Founded by engineers with distributed-systems and real-time autonomous-software backgrounds.

Legal name
Talyra Technologies, Inc.
CAGE
23X97
Location
Lake Forest, California

For Investors

For investors

Investment and Strategic Partners

We welcome conversations with investors and strategic partners interested in decentralized autonomy, resilient coordination, and the future of unmanned systems.

Connect with our team to discuss investment opportunities and strategic collaboration supporting Talyra’s next stage of development.

Contact Our Team

Contact

Request a briefing.

Customer and program inquiries, platform and C2 integration, investment and strategic partnerships.

You can also write to us directly at [email protected].